Rotational mechanics
Torque, inertia, viscous friction and the conversion between angular speed and rpm.
Before you begin: the rotational equation of motion and kinetic energy.
After this lesson you can: refer inertia and load to one shaft, assess local stability and identify the limits of a single-mass model.
Work through the explanation, examples, practical experiment and independent exercises.
From force to torque
Torque plays the role of force, and moment of inertia the role of mass. Two rotors of equal mass can accelerate differently because their mass distributions differ. Our rigid-shaft model represents all referred inertia by J. A positive signed load torque is subtracted. Under reversal, a constant signed torque and a torque that always opposes motion are different load models.
Speed and units
Use rad/s in the equations. A speed of 1500 rpm is 157.08 rad/s. Substituting 1500 as angular speed corrupts back EMF, friction and power; stored kinetic energy has an even larger error because it depends on speed squared.
Acceleration and coast-down
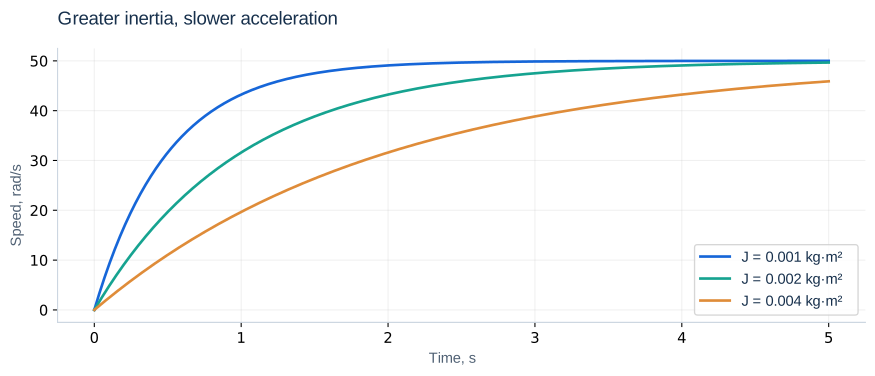
With constant net applied torque M = Me − ML and b > 0, the mechanical time constant is J/b and final speed M/b. For J = 0.002 kg·m², b = 0.002 N·m·s/rad and M = 0.1 N·m, these are 1 s and 50 rad/s. Increasing inertia slows the response without changing equilibrium. Initial acceleration from rest is M/J. With no friction, a constant nonzero torque produces unlimited linear growth.
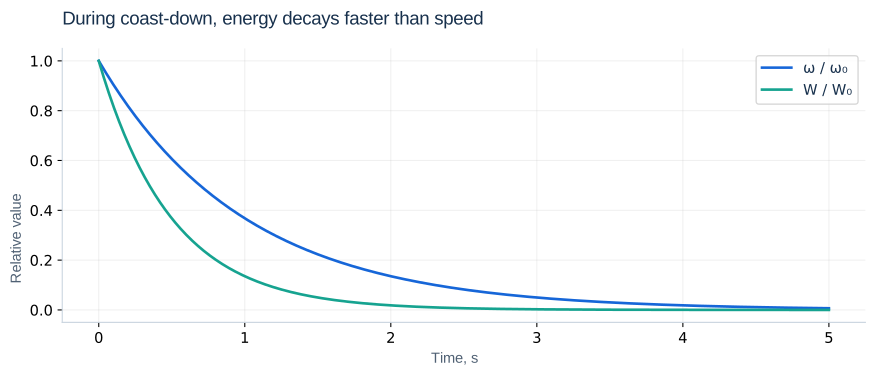
With no applied or load torque and only viscous friction, speed approaches zero asymptotically. Real dry friction can stop a shaft in finite time, but is absent here. At ω₀ = 100 rad/s, the initial energy is 10 J. After one mechanical time constant, 36.8% of speed but only 13.5% of energy remains.
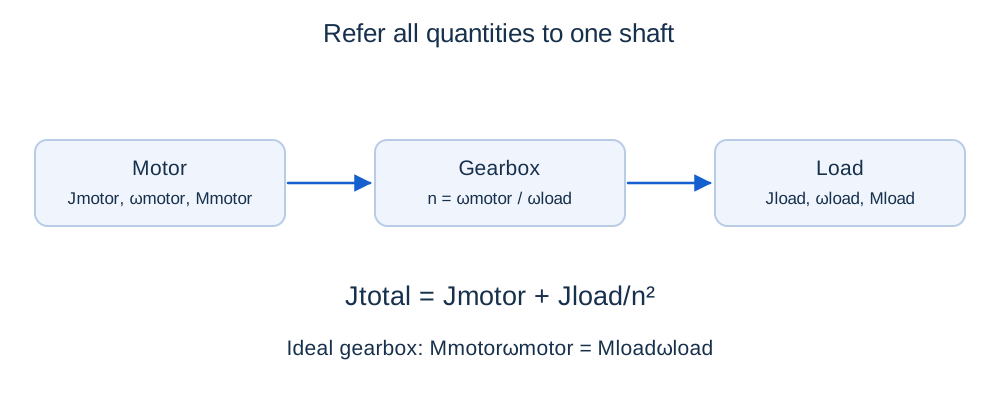
Referring a mechanism to the motor shaft
Jtotal = Jmotor + Jload/g²; Mload,referred = Mload/g
Jtranslation = m(v/ωmotor)²
An ideal gearbox preserves kinetic energy and power. A translating mass on a drum of radius r contributes mr² without gearing, or m(r/g)² at the motor shaft. For efficiency η and power flowing from motor to load, required torque is Mload/(ηg). Reverse power flow needs its own loss convention.
Example: Jmotor = 0.002, Jload = 0.08 kg·m² and g = 10 give Jtotal = 0.0028 kg·m². A 2 N·m load refers to 0.2 N·m. With motor torque 0.3 N·m and negligible friction, acceleration is 35.71 rad/s².
Nonlinear load and local stability
JΔω′ ≈ F′(ω*)Δω; τlocal = −J/F′(ω*)
A fan load with c > 0 reverses sign with speed and always absorbs power. An equilibrium is locally stable when F′(ω*) < 0. At positive speed with constant motor torque, F′ = −2cω* − b. The resulting time constant describes small deviations near the operating point, not the entire startup.
When a second inertia is needed
J₁ω₁′ = Me − Ms; J₂ω₂′ = Ms − ML
θ′ = ω₁ − ω₂
A flexible shaft, coupling or belt stores elastic energy, allowing motor and load speeds to differ. With no external torques or damping, the relative natural frequency is √[k(1/J₁ + 1/J₂)]. If it approaches an excitation frequency or controller bandwidth, a single inertia hides resonance. A stiff connection and slow changes may justify the simpler model.
Independent exercises
1. A 5 kg mass is driven by a 0.1 m drum through an ideal gearbox g = 5. Find its referred inertia.
Show solution
J = m(r/g)² = 0.002 kg·m². Add motor, drum and gearbox inertias separately.
2. At J = 0.01, b = 0.002, c = 10⁻⁴ and ω* = 40 rad/s, find equilibrium torque and local time constant.
Show solution
Me = bω* + cω*² = 0.24 N·m. τ = J/(b + 2cω*) = 1 s. A large torque step can depart substantially from the local linear approximation.
Practical work
Calculate coast-down from 100 to 10 rad/s: t = (J/b) ln 10 = 2.303 s for J = b = 0.002 in SI units. Double inertia and check that the time doubles. Explain why zero motor torque does not mean zero speed, and justify using one or two masses.
Calculated illustrations
Key takeaways
The sum of torques determines motion. Inertia sets acceleration and friction dissipates energy. Check units and load signs, particularly when speed reverses.
Progress is stored only in this browser.